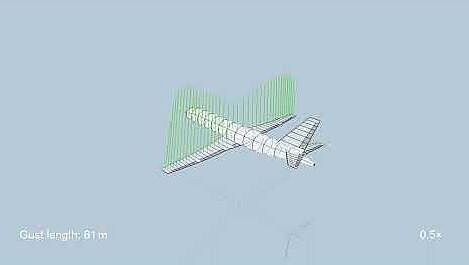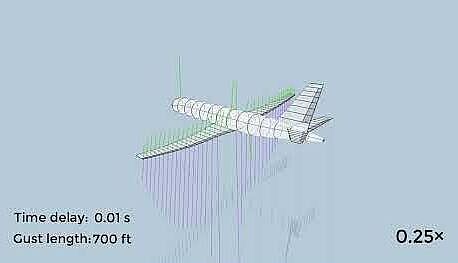

The implemented active gust load alleviation system controls the deflection, velocity, and acceleration of the first and second bending modes and, depending on the control system’s response time, results in a greater or lesser reduction in wing deflection and, consequently, in gust loads.
This is the first instance of compensating for a complete motor failure in a quadcopter without explicit knowledge of the failure. Since the system is underactuated after the motor failure, control of the yaw axis is abandoned, and the quadcopter rotates around the vertical axis.
Dive Mode allows a copter to descend quickly and automatically from high altitudes. This conserves energy and increases safety when manned aircraft are approaching. This project was carried out in collaboration with the Meteorology and Flight Measurement Technology Working Group.
The core of the projects is the LADAC framework, which provides modules for flight dynamics and flight control.